
Engineer's Toolbox
Visit www.hansarobotics.com
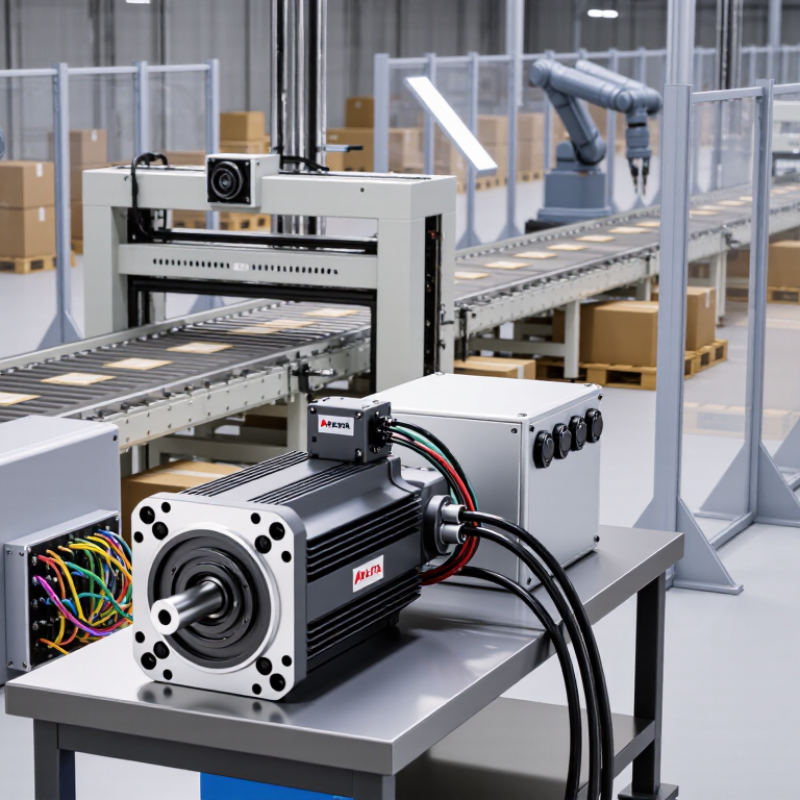
How to Choose a Delta Servo Motor in 2026 is not just a model-number exercise. A motor that looks powerful on paper can still miss a machine’s real duty cycle. Consider a packaging axis that accelerates repeatedly, then holds position while a camera checks a label. Peak torque, continuous torque, inertia matching, and settling time all matter. So do the drive, encoder, cable, and control interface.
The automation context is substantial. The International Federation of Robotics reported 541,302 industrial robot installations worldwide in 2023, in its World Robotics 2024 report. That figure signals sustained demand for motion systems, but it does not prove that every application needs a larger servo. Fit matters more than headline power. For a Delta Servo Motor, compare the load’s reflected inertia and required speed with the manufacturer’s motor-and-drive data. Check supply voltage, braking needs, ambient temperature, protection rating, and controller compatibility. Then validate the choice against real acceleration and stopping profiles, not only nominal speed.
Small details count. A cable bend can constrain installation. So can limited cabinet space or a machine frame that transfers heat poorly. Review the selected model’s performance curves and confirm that the drive supports the intended feedback and communication setup. If the load changes often, leave room for a careful recalculation. A spreadsheet estimate is useful, but it can hide friction, shock loads, or imperfect mechanics. That is worth admitting. Before purchase, verify the sizing with measured machine data and Delta’s current technical documentation. This guide lays out the checks that help engineers choose confidently, without treating a catalog rating as a guarantee.
Begin by describing the actual task, not just the machine’s rated speed. Is the motor moving a light indexing table, a loaded conveyor, or a vertical axis? Record the moving mass, travel distance, acceleration time, and stopping frequency. A 12-kilogram carriage that starts and stops every two seconds places different demands on a servo than one moving steadily. Details matter. Include friction, gearbox ratio, and any load changes; leaving them out can make an early estimate misleading.
Next, map the motion profile and duty cycle. Note peak speed, peak torque, and how long each move lasts, then estimate RMS torque across the full operating cycle. Peak torque affects acceleration, while RMS torque helps assess heating during repeated operation. Check the motor’s torque-speed curve at the intended supply voltage, not just its headline rating. For vertical loads, account for gravity and braking requirements. A margin can be useful, but oversized motors may add cost and inertia. Not just speed. Treat calculations as a starting point, then verify them against the drive, feedback device, ambient conditions, and the machine’s real cycle. If the load or cycle is uncertain, measure it before final selection.
| Selection Dimension | What to Define | How to Evaluate It | Illustrative Example |
|---|---|---|---|
| Application and axis type | Identify what the axis moves and whether its motion is rotary, linear, vertical, or coordinated with other axes. | Record the machine function, travel range, required positioning accuracy, repeatability, and any synchronization requirements. Confirm whether the axis must hold position when stopped. | A packaging machine may use a rotary axis for indexing and a linear axis for feeding film; these axes can have different speed and accuracy requirements. |
| Load and mechanics | List the moving mass or load inertia, transmission type, pulley or screw dimensions, friction, and any external forces. | Include the inertia of the load and transmission components reflected to the motor shaft. For a rotary load, inertia depends on mass distribution; for a linear axis, convert mass and transmission geometry into equivalent motor-side inertia. | A ball-screw axis needs the moving mass, screw lead, screw inertia, coupling inertia, and estimated friction—not just the payload mass. |
| Speed and travel | Define maximum and typical speed, travel distance or rotation, and the time available for each move. | Check that the required speed is within the motor and drive limits and that the transmission does not exceed its permitted speed. Account for the effect of gearing or screw lead. | For a screw with a 10 mm lead, a screw speed of 600 rpm corresponds to 6,000 mm/min of linear speed, before considering other system limits. |
| Motion profile | Specify acceleration, deceleration, dwell time, and whether motion is trapezoidal, triangular, or follows an S-curve. | Estimate acceleration torque from the total motor-side inertia and angular acceleration: T = J × α. Add torque required to overcome gravity, friction, and process forces. Use consistent SI units. | A short move with limited time may require high acceleration torque even when its maximum speed is modest. An S-curve can reduce abrupt changes in acceleration but may require a different move time. |
| Torque and speed match | Compare required torque across the complete move with the motor’s available torque at the corresponding speed. | Check the motor-drive torque-speed data, including continuous and peak limits. Peak torque is generally intended for short-duration demands; it should not be treated as a continuous rating. | Plot or calculate torque during acceleration, constant-speed travel, and deceleration, then verify every part of the profile against the applicable operating limits. |
| Duty cycle and heating | Record the cycle time, move time, dwell time, number of cycles per hour, and how often peak torque is required. | Evaluate the repeated load over the full cycle, not only the highest torque. A common first check is equivalent RMS torque: TRMS = √(Σ(Ti2ti) / Σti). Compare it with the applicable continuous rating and follow the motor and drive manufacturers’ thermal guidance. | A motor that meets a brief peak-torque demand may still overheat if high torque is repeated frequently or the dwell time is too short for cooling. |
| Vertical and regenerative loads | Identify gravity-driven motion, overhauling loads, and frequent deceleration or stopping. | Calculate the torque needed to raise or lower the load. Check whether the drive can manage regenerated energy and whether a braking resistor or mechanical brake is required by the system design. | A vertical axis may need a brake to hold the load when power is removed; servo holding torque alone should not automatically be treated as a safe load-holding method. |
| Feedback and control | Define the required position feedback, control mode, communication interface, and response to faults or loss of power. | Match the encoder and drive capabilities to required resolution, positioning performance, controller compatibility, and machine safety architecture. Resolution alone does not determine system accuracy. | An axis requiring coordinated motion should use a feedback and communication setup supported by the motion controller and drive, with synchronization verified at system level. |
| Environment and installation | Record ambient temperature, dust, moisture, washdown exposure, vibration, mounting orientation, and available space. | Check enclosure protection, temperature limits, cooling requirements, cable routing, shaft and mounting compatibility, and any derating required by the selected installation conditions. | A motor installed in a hot enclosure or exposed to frequent washdown may require a different protection and thermal arrangement than one installed in a clean, ventilated cabinet. |
| Final verification | Confirm the selected motor, drive, transmission, brake, cables, and controller as one system. | Validate torque-speed margin, peak duration, RMS torque, inertia, stopping behavior, thermal performance, and fault handling using the actual motion profile. Test under representative operating conditions. | Use measured cycle data from a prototype or machine trial to refine estimates before finalizing the selection. |